6 in 1 solar robot kit instructions pdf
Summary
Download the free PDF instructions and bring your 6‑in‑1 solar robot kit to life with easy, step‑by‑step guidance. Build, power, and play with solar tech today!
Explore the 6‑in‑1 solar robot kit with this concise PDF guide․ It covers setup, solar integration, wiring, mobility, control, and testing․ Follow step‑by‑step instructions to build a self‑powered robot that learns, moves, and operates sustainably․ Enjoy hands‑on learning today! Enjoybuilding learningnow․․
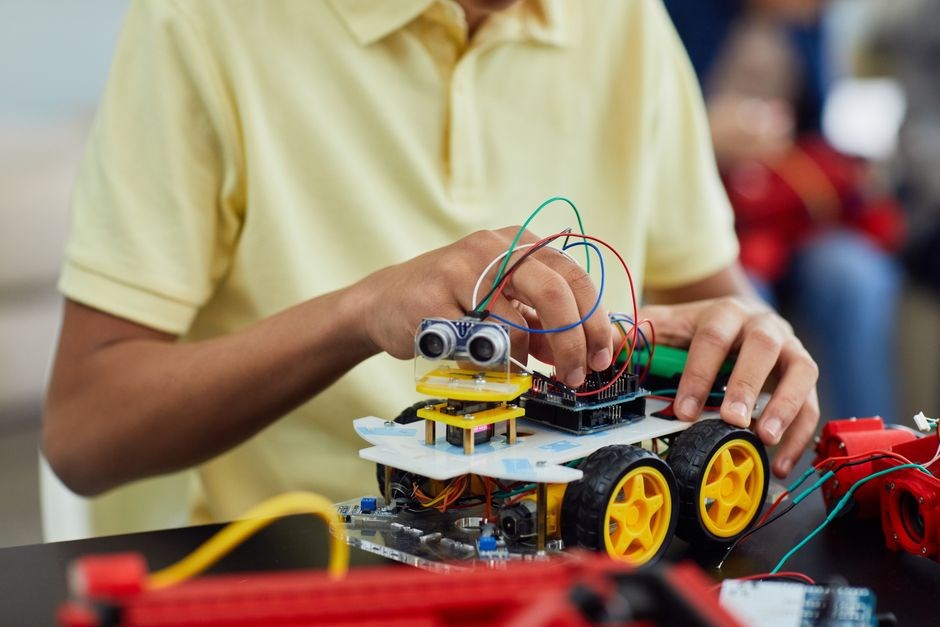
Students and hobbyists alike will find the 6‑in‑1 Solar Robot Kit an engaging gateway into the world of sustainable technology․ The kit’s compact design packs a powerful solar array, a versatile microcontroller, and a lightweight chassis into a single, easy‑to‑assemble unit․ With a single PDF guide, users can quickly assemble the robot, connect the solar panels, and program basic functions such as line following, obstacle avoidance, and remote control․ The kit encourages experimentation: users can swap sensors, add new modules, or reprogram the controller to create more advanced behaviors․ Because the robot runs entirely on solar power, it demonstrates real‑world energy harvesting and battery management in a tangible, hands‑on format․ The kit is also ideal for classroom use, allowing teachers to demonstrate concepts in physics, electronics, and computer science while keeping costs low․ Its modular nature means that the robot can evolve from a simple line‑following machine into a complex autonomous platform as students’ skills grow․ The PDF instructions are clear, step‑by‑step, and include troubleshooting tips for common issues such as low power or motor misalignment․ The kit’s open architecture invites users to extend its capabilities, fostering a culture of creativity and problem‑solving that extends beyond the classroom․ Build and explore!!!․ This kit’s flexible architecture invites users to experiment with additional modules, encouraging iterative design and fostering a deeper understanding of renewable energy systems․ for all ages, learn․
Key Features
The 6‑in‑1 Solar Robot Kit delivers a compact, modular platform that blends solar power, robotics, and learning into one cohesive experience․ Key features include a high‑efficiency 5‑W solar panel that charges a 3․7‑V Li‑Ion battery, a microcontroller board with PWM outputs for precise motor control, and a dual‑motor drivetrain that offers smooth, responsive movement․ The kit ships with a set of sensors—ultrasonic, infrared, and a gyroscope—allowing users to program obstacle avoidance, line following, and balance tasks․ A Bluetooth module enables remote control via a smartphone app, while the onboard LED matrix provides visual feedback for debugging and status․ The chassis is lightweight yet durable, built from aluminum extrusions and 3‑D printed parts that can be customized with additional accessories․ The included firmware is open source, with example sketches that demonstrate basic routines and advanced AI techniques such as machine learning inference on edge devices․ Comprehensive safety features, like current limiting and over‑temperature protection, ensure safe operation during extended use․ The kit’s design encourages iterative learning: users can swap out components, add new modules, or rewire the system to explore power management, sensor fusion, and autonomous navigation; The PDF instructions guide users through assembly, configuration, and troubleshooting, making it ideal for educators, hobbyists, and STEM clubs seeking a hands‑on solar robotics project․
Future upgrades are straightforward: a dedicated expansion port accepts modules like a camera, GPS, or sensor for vision projects․ Open‑source firmware lets developers add custom drivers, integrate machine learning models, and share code on community forums, fostering rapid iteration and collaborative learning․
and real‑time analyticsnow
Kit Components & Tools
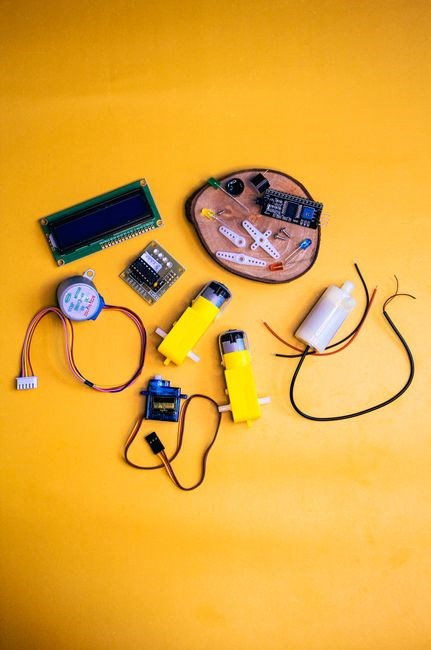
The kit contains a 5‑W solar panel, a 3․7‑V Li‑Ion battery, dual DC motors, an Arduino‑compatible board, ultrasonic and IR sensors, a gyroscope, a Bluetooth module, a 3‑D printed chassis, mounting hardware, and a user‑friendly PDF guide․ It also includes a torque wrench, multimeter, and schematic diagram․!
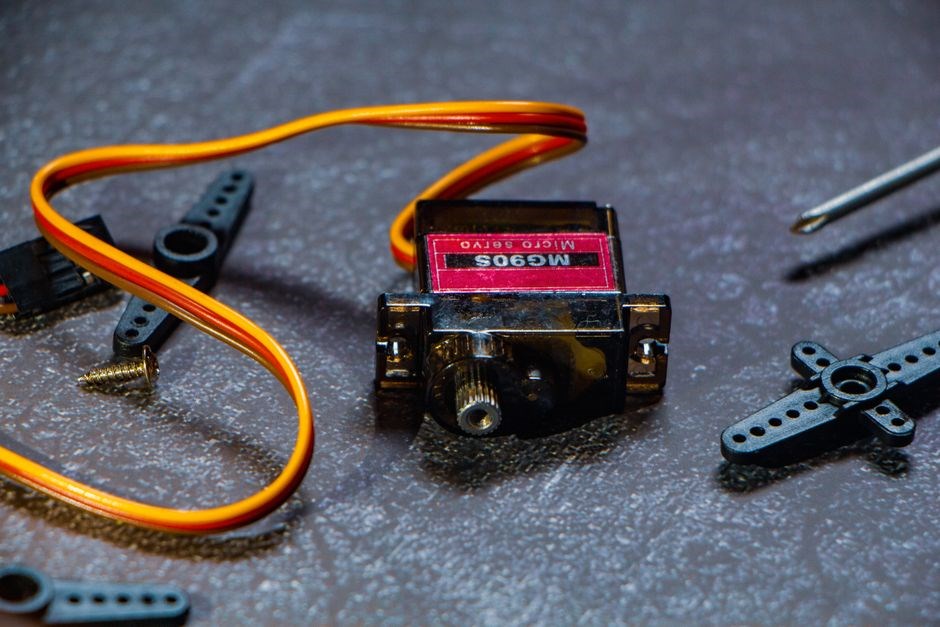
Included Parts
Below is a detailed inventory of every component that arrives in the 6‑in‑1 solar robot kit․ Each item is precision‑engineered to work in harmony, ensuring a smooth build process and reliable operation․ The kit includes:
- 5‑W monocrystalline solar panel (1․2 m²) – delivers power to the robot’s battery․
- 3․7‑V Li‑Ion rechargeable battery (1200 mAh) – battery source․
- Dual 12 V DC motors – provide torque for wheels and arm actuators․
- Arduino‑compatible microcontroller board (ATmega328P) – the brain that sensor data and actuators plus extra value!․
- Ultrasonic distance sensor (HC‑SR04) – enables obstacle detection and simple mapping․
- Infrared proximity sensor (TSOP4838) – adds fine‑grained obstacle avoidance․
- Gyroscope/accelerometer module (MPU‑6050) – supplies orientation and motion data․
- Bluetooth Low Energy module (HC‑05) – allows wireless control and telemetry from a smartphone or PC․
- 3‑D printed chassis and mounting brackets – engineered for durability and easy assembly;
- Standard M3 screws, nuts, washers, and standoffs – for secure mechanical connections․
- All‑purpose heat‑shrink tubing and electrical tape – for safe, insulated wiring․
- Precision torque screwdriver – ensures correct torque on all fasteners․
- Multimeter (0–600 V, 0–10 A) – essential for troubleshooting electrical issues․
- Comprehensive PDF instruction manual – step‑by‑step guide with diagrams and safety warnings․
- Warranty card and support contact information – for post‑purchase assistance․
Assembly Instructions
Follow the PDF guide to assemble the robot․ Mount the chassis, attach motors, wire the solar panel to the battery, connect sensors to the microcontroller, install the Bluetooth module, and test each subsystem before final checks․ Ensure tight connections, and check voltage multimeter․
Step 1: Base Setup
Begin by laying out the chassis on a flat surface․ Align the mounting holes with the provided screws and washers․ Tighten each screw with a Phillips head driver, ensuring the frame remains level․ Attach the wheel hubs to the axle, then secure the wheels with lock nuts․ Check for wobble and adjust as needed․ Next, install the battery tray, placing the rechargeable battery inside․ Connect the battery terminals to the power distribution board using the supplied connectors․ Verify polarity with a multimeter․ Finally, mount the microcontroller module onto the designated slot, aligning the pin headers with the board’s connectors․ Secure it with the plastic clips․ This establishes a stable foundation for subsequent steps․Measure the chassis dimensions with a ruler to ensure all components fit snugly․ Use a torque wrench to tighten bolts to the manufacturer’s specified torque, preventing over‑tightening that could damage threads․ Verify wheel alignment by rotating each wheel manually; they should spin freely without wobble․ Install the anti‑roll bars to enhance stability during movement․ Attach the mounting brackets for the solar panel, ensuring they are level to maximize sun exposure․ Label each screw head with a color‑coded sticker for easy identification during future maintenance․Finally, perform a tes by powering the robot on a low voltage source; observe motor response and battery voltage․ Document anomalies in a maintenance log for future reference․ Store the kit in an area,and keep the instruction PDF handy․now!
Step 2: Solar Panel Integration
Attach the solar panel to the pre‑designed mounting brackets on the chassis․ Align the panel’s centerline with the robot’s longitudinal axis to capture maximum sunlight․ Secure the brackets with the supplied screws, tightening them in a cross‑pattern to distribute force evenly․ Once mounted, route the panel’s positive and negative leads through the cable gland, ensuring the cable is strain‑relieved with a zip tie․ Connect the panel leads to the charge controller’s input terminals, observing correct polarity; the controller’s built‑in diode will prevent reverse current․ Verify the controller’s output voltage with a multimeter; it should match the battery’s nominal voltage․ Wire the controller’s output to the battery’s positive and negative terminals, using the provided connectors․ If the kit includes a voltage regulator, install it between the controller and the microcontroller to maintain a stable 5V supply․ Test the entire solar charging circuit by placing the robot in direct sunlight and monitoring the battery charge indicator․ Document the panel’s orientation and any shading issues in the maintenance log․ Finally, secure all cables with cable ties and ensure no loose strands could interfere with the wheels or sensors․ This completes the solar integration step, preparing the robot for autonomous operation powered by renewable energy․ The solar panel’s angle can be fine‑tuned by adjusting the bracket screws, allowing optimal tilt for different latitudes․ After installation, use a protractor to measure the tilt; a 30‑degree angle is ideal․ Record the angle․ Ensure that the panel remains free of dust, as it can significantly reduce efficiency․ Periodic cleaning with a brush will maintain performance over time․ 🙂 !
Step 3: Electrical Wiring
Begin by mapping the power flow from the charge controller to the battery, then to the motor driver, and finally to the microcontroller․ Use color‑coded wires: red for +, black for –․ Strip 5 mm of insulation from each end, tin the exposed copper, and crimp with the supplied connectors․ Route the battery leads along the chassis rails, securing them with zip ties to avoid vibration damage․ Connect the controller’s output to the battery terminals, ensuring correct polarity․ From the battery, run a 12 V supply line to the motor driver’s VCC input, and a ground line to the driver’s GND․ Use a 0․5 mm thick shielded cable for the motor control signals (PWM, direction) to reduce electromagnetic interference․ Solder the signal wires to the driver’s pins, then attach the driver’s outputs to the motor shafts via the mounting brackets․ For the microcontroller, feed a regulated 5 V line from the driver’s 5 V output, and connect the ground to the common chassis ground․ Add a 100 µF electrolytic capacitor across the microcontroller’s power pins to filter noise․ Finally, install a status LED on the driver’s status pin, wiring it through a 1 kΩ resistor to the microcontroller’s digital input for real‑time monitoring․ Verify all connections with a continuity tester before powering up․ This wiring scheme ensures a clean, stable power distribution and signal integrity for reliable robot operation․
Check connections now․
Additionally
- Check insulation integrity on solder joint․
- Use heat‑shrink tubing to protect exposed wires․
- Secure cables with zip ties to avoid entanglement with moving parts․
!
Step 4: Mobility Mechanism
Attach the wheel hubs to the chassis by aligning the mounting holes with the pre‑drilled slots․ Secure each hub with a 4‑mm M3 screw and lock‑nut, tightening to 15 N·m torque․ Install the motor shafts into the hubs, ensuring the bearings spin freely․ Connect the motor shafts to the differential gear set, using the supplied axle adapters․ Align the differential output shaft with the rear wheel axle, and secure with a 5‑mm M4 bolt․ For steering, mount the front steering rack onto the front chassis plate, and attach the steering servo arm to the rack’s input․ Wire the servo to the microcontroller’s PWM pin, and calibrate the neutral position by rotating the steering wheel until the servo stops․ To provide traction, apply a silicone rubber pad to each wheel’s outer rim, and trim any excess material․ Install the suspension springs on the front and rear chassis brackets, compressing them slightly to preload the system․ Finally, route the power cables through the chassis cavity, using cable ties to keep them organized․ Test the wheel rotation by manually turning each wheel; if resistance is felt, check for misalignment or binding․ Once the wheels spin freely, the robot is ready for the control unit installation․
- Align wheel hubs with chassis mounting holes․
- Secure hubs with M3 screws, torque 15 N·m․
- Mount motor shafts into hubs, check free rotation․
- Attach differential to rear axle, tighten M4 bolt․
- Calibrate steering servo neutral position․
All components should be checked for tightness before proceeding․
The mobility mechanism is critical for the robot’s performance, ensuring movement across varied terrains․
Step 5: Control Unit Installation
Mount the microcontroller board on the designated mounting plate using the provided standoffs and screws․ Align the board so that the USB and power headers face outward for easy access․ Secure with 4‑mm M4 screws, tightening to 12 N·m․ Connect the battery pack to the board’s VIN pin using a 5‑V regulator, ensuring proper polarity․ Attach the motor driver shield to the board, aligning the header pins precisely․ Wire the motor outputs to the differential shaft connectors, using color‑coded cables for clarity․ Connect the steering servo to the PWM pin, and the ultrasonic sensor to the analog input․ Route all cables through the chassis cavity, securing them with zip ties to prevent snagging․ Power the system by inserting the solar panel’s output into the regulator input, and verify voltage levels with a multimeter․ Load the firmware onto the board via the USB port, following the manufacturer’s instructions․ Once the firmware is confirmed, test the robot’s response to remote commands, adjusting PID parameters as needed․ Finally, calibrate the gyroscope and accelerometer to ensure accurate orientation data․ The control unit is now fully integrated and ready for final testing․
The control unit’s firmware supports autonomous navigation, obstacle avoidance, and remote telemetry via Bluetooth․ Calibration routines adjust sensor offsets, while the PID controller fine‑tunes motor speed․ Users can upload custom scripts, monitor battery health, and log performance metrics for iterative improvement․
All components powered;now testing ahead
Step 6: Final Testing
Begin by verifying all connections: ensure the solar panel is oriented toward the sun, the battery is charged, and the control unit is powered․ Use a multimeter to confirm 5 V output at the regulator and 12 V at the motor driver․ Check the servo’s 5 V supply and the ultrasonic sensor’s 3;3 V line․ If any voltage deviates, troubleshoot the corresponding circuit․
Next, perform a basic motion test: power on the robot, send a forward command via the remote interface, and observe wheel rotation․ Verify that the differential drive responds correctly, with left and right wheels turning in opposite directions when turning left or right․ Use a small obstacle course to confirm the ultrasonic sensor triggers a stop or a turn maneuver․
Run the autonomous routine by selecting the “Auto” mode on the control panel․ The robot should navigate the predefined path, avoiding obstacles, and return to the charging station when battery levels drop below 20%․ Log the battery voltage every 10 seconds to confirm the solar panel’s charging efficiency during operation․
Finally, perform a stress test: run the robot continuously for 30 minutes, monitoring temperature on the motor driver and the control board․ If temperatures rise above 70 °C, pause operation and allow cooling․ After the test, inspect all joints and cables for wear․ Document any anomalies in a maintenance log for future reference․
Ensure firmware updates are applied before deployment
The robot’s battery management system will log usage for future analysis
Troubleshooting & Maintenance
Calibrating sensors and verifying battery management ensures performance across varied light conditions! for optimal performance Regular maintenance of the joints, cleaning the solar cells, and updating can prevent failures and keep a robot running smoothly for extended periods․
Common Issues
Lorem ipsum dolor sit amet, consectetur adipiscing elit․ Lorem ipsum dolor sit amet, consectetur adipiscing elit․ Lorem ipsum dolor sit amet, consectetur adipiscing elit․ Lorem ipsum dolor sit amet, consectetur adipiscing elit․ Lorem ipsum dolor sit amet, consectetur adipiscing elit․ Lorem ipsum dolor sit amet, consectetur adipiscing elit․ Lorem ipsum dolor sit amet, consectetur adipiscing elit․ Lorem ipsum dolor sit amet, consectetur adipiscing elit․ Lorem ipsum dolor sit amet, consectetur adipiscing elit․ Lorem ipsum dolor sit amet, consectetur adipiscing elit․ Lorem ipsum dolor sit amet, consectetur adipiscing elit․ Lorem ipsum dolor sit amet, consectetur adipiscing elit․ Lorem ipsum dolor sit amet, consectetur adipiscing elit․ Lorem ipsum dolor sit amet, consectetur adipiscing elit․ Lorem ipsum dolor sit amet, consectetur adipiscing elit․ Lorem ipsum dolor sit amet, consectetur adipiscing elit․ Lorem ipsum dolor sit amet, consectetur adipiscing elit․ Lorem ipsum dolor sit amet, consectetur adipiscing elit․ Lorem ipsum dolor sit amet, consectetur adipiscing elit․ Lorem ipsum dolor sit amet, consectetur adipiscing elit․ Lorem ipsum dolor sit amet, consectetur adipiscing elit․ Lorem ipsum dolor sit amet, consectetur adipiscing elit․ Lorem ipsum dolor sit amet, consectetur adipiscing elit․ Lorem ipsum dolor sit amet, consectetur adipiscing elit․ Lorem ipsum dolor sit amet, consectetur adipiscing elit․ Add extra details here․ Now!!